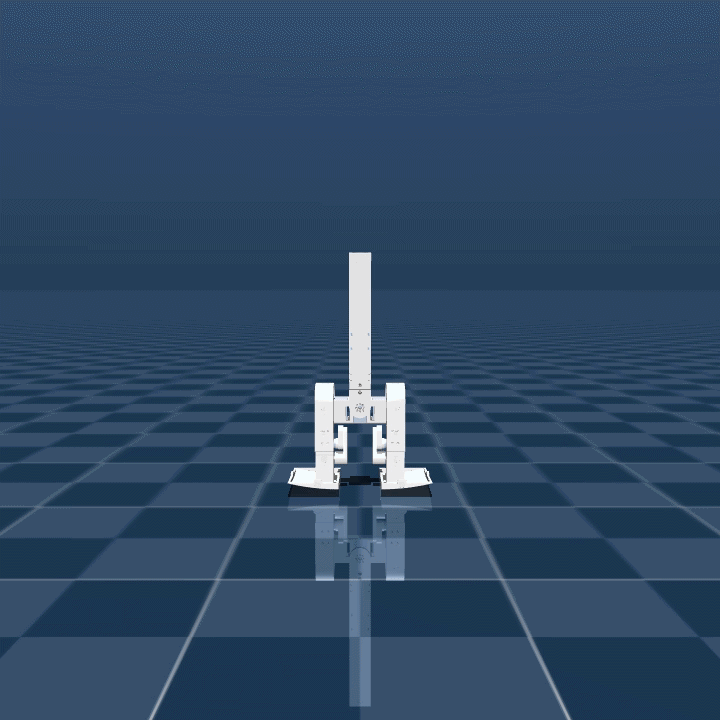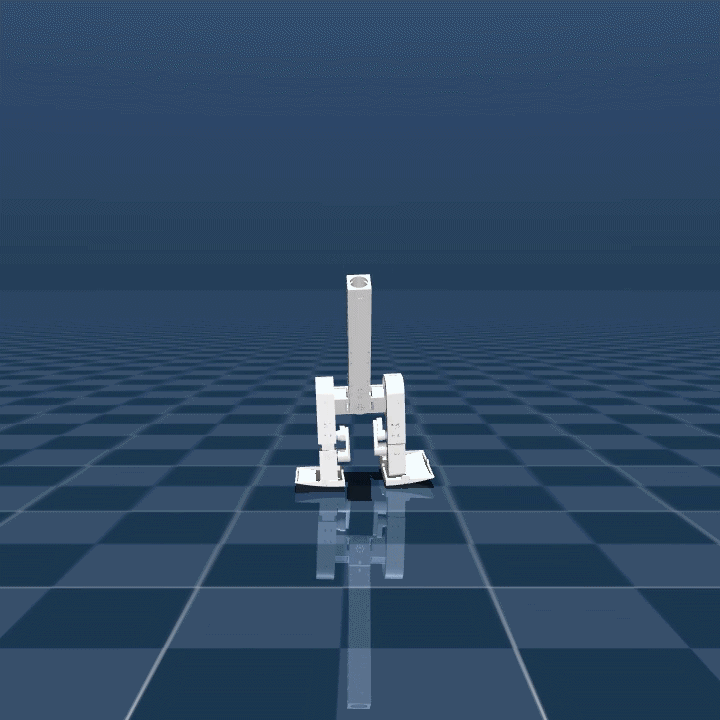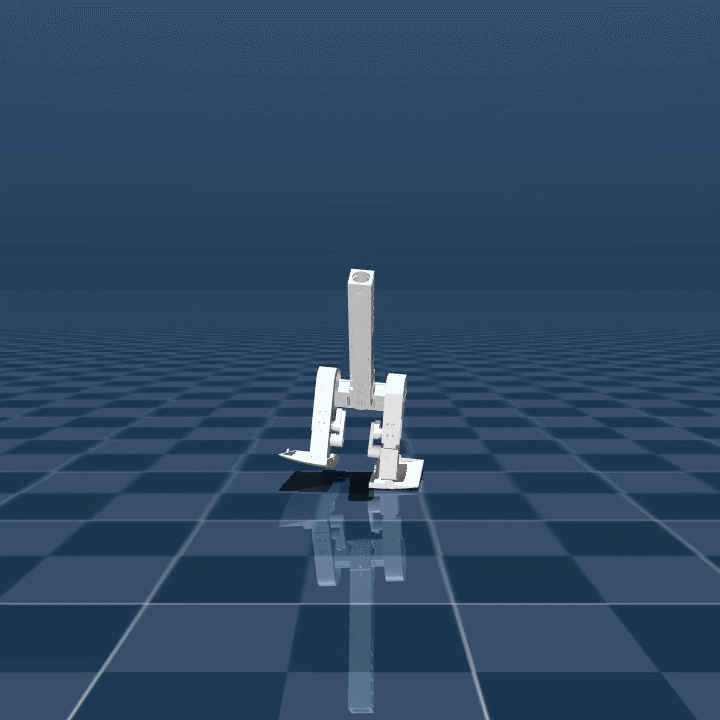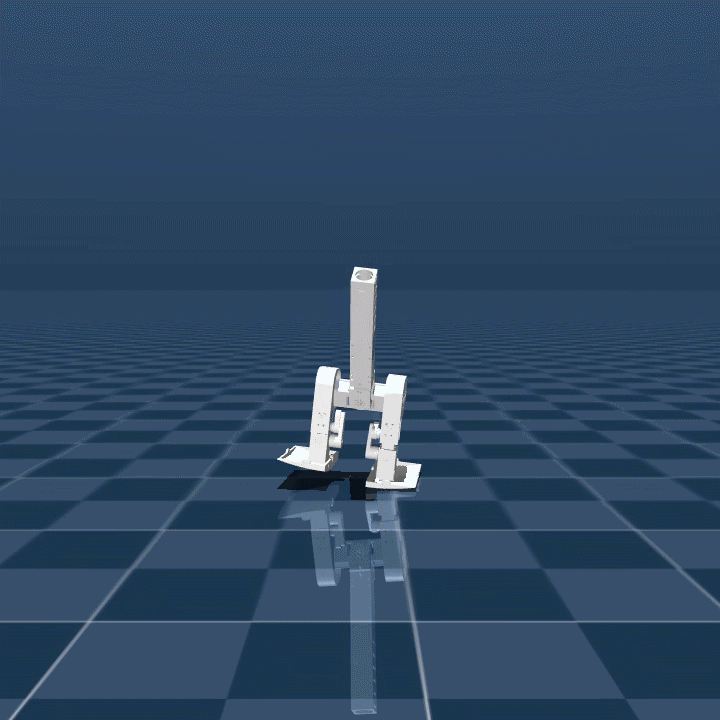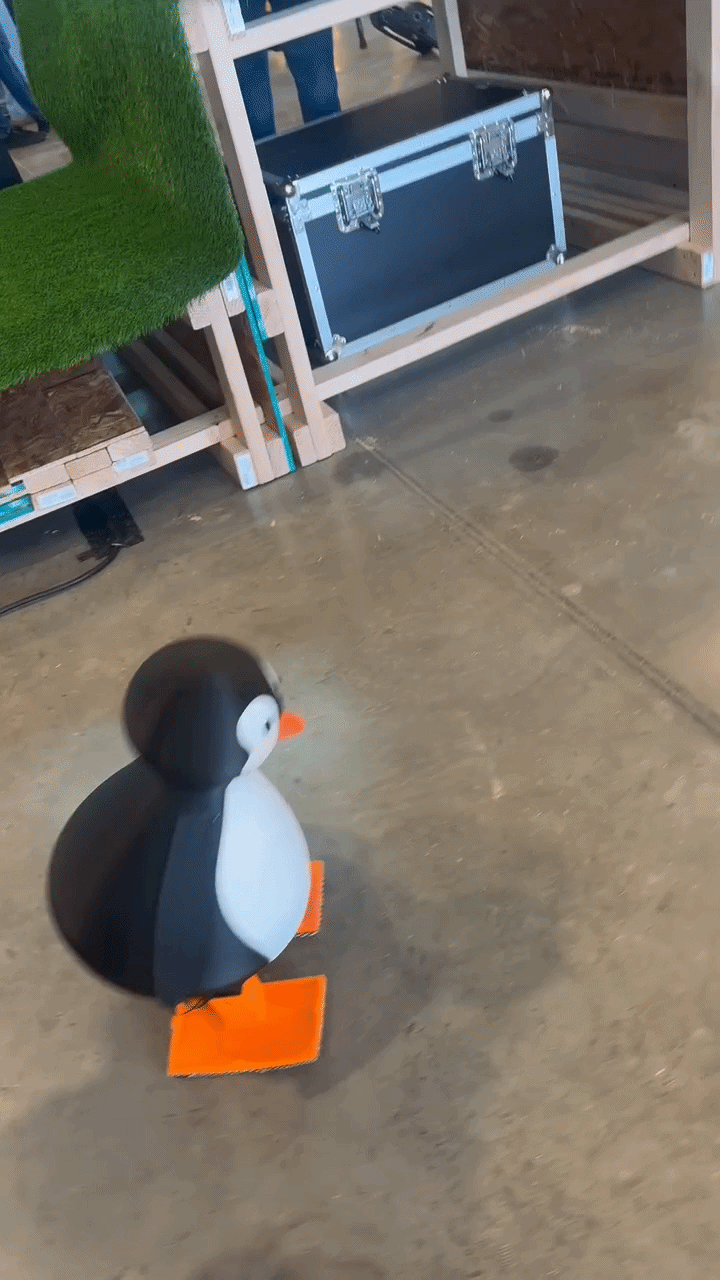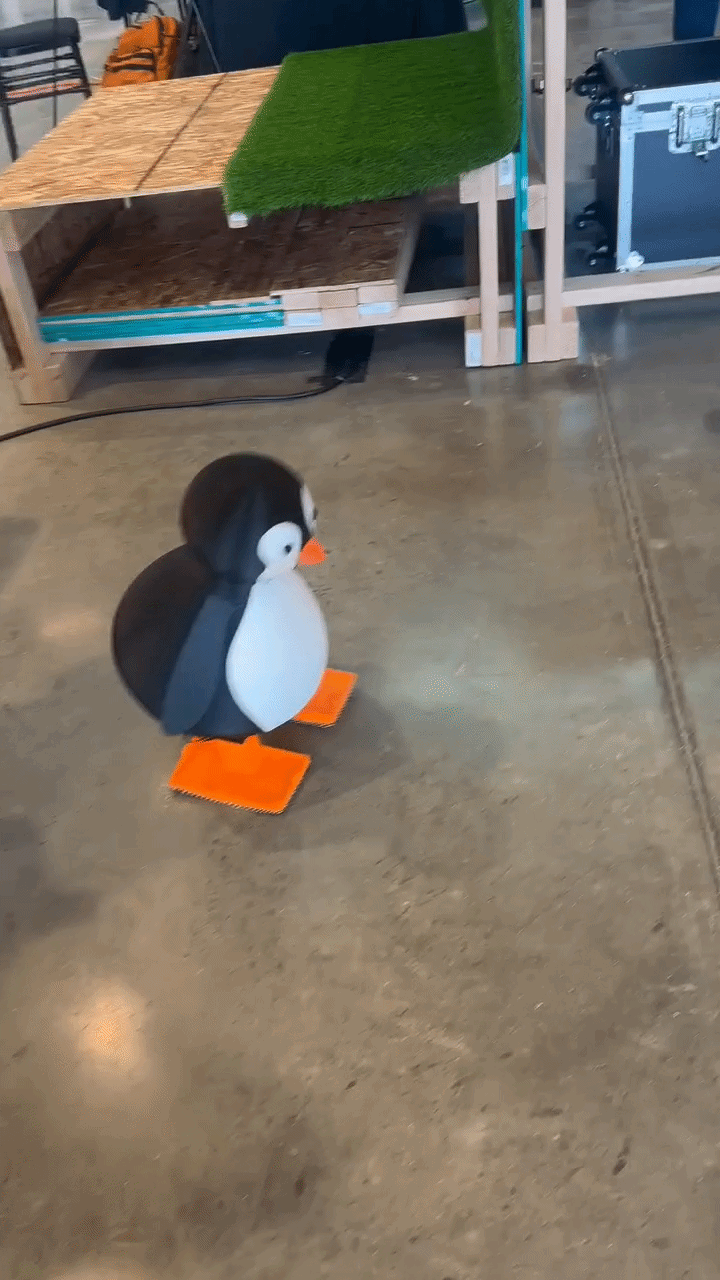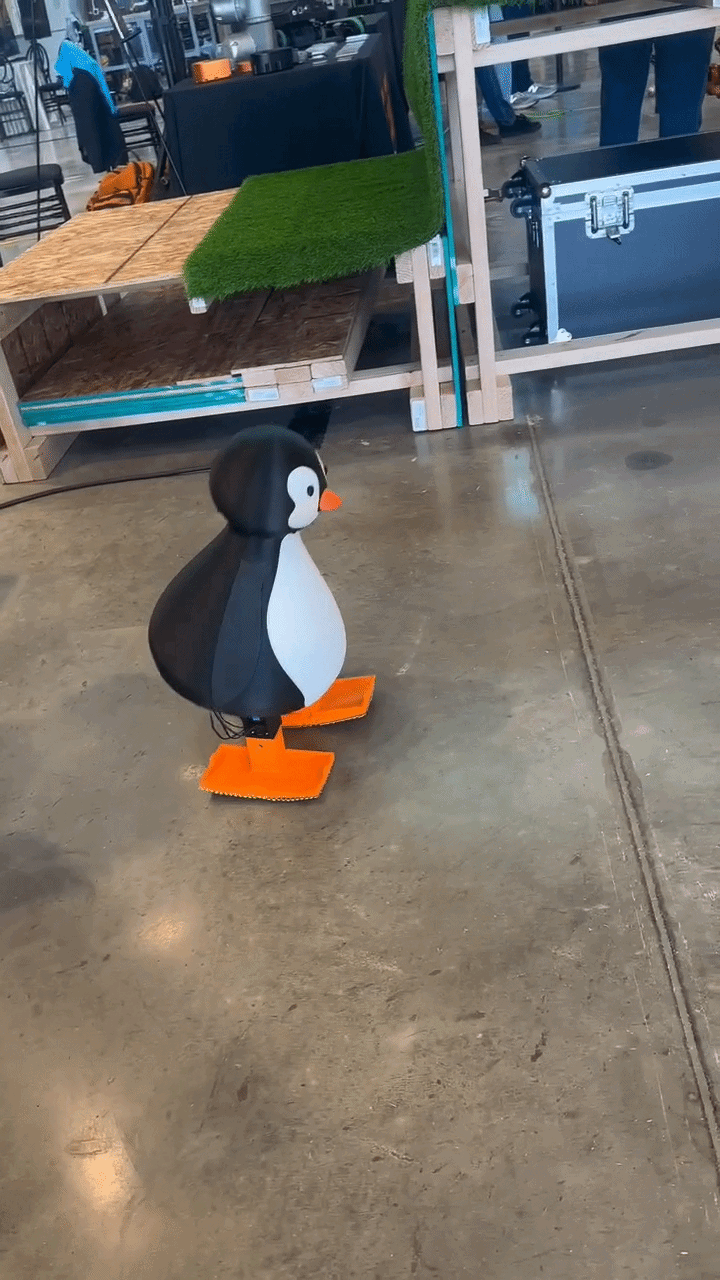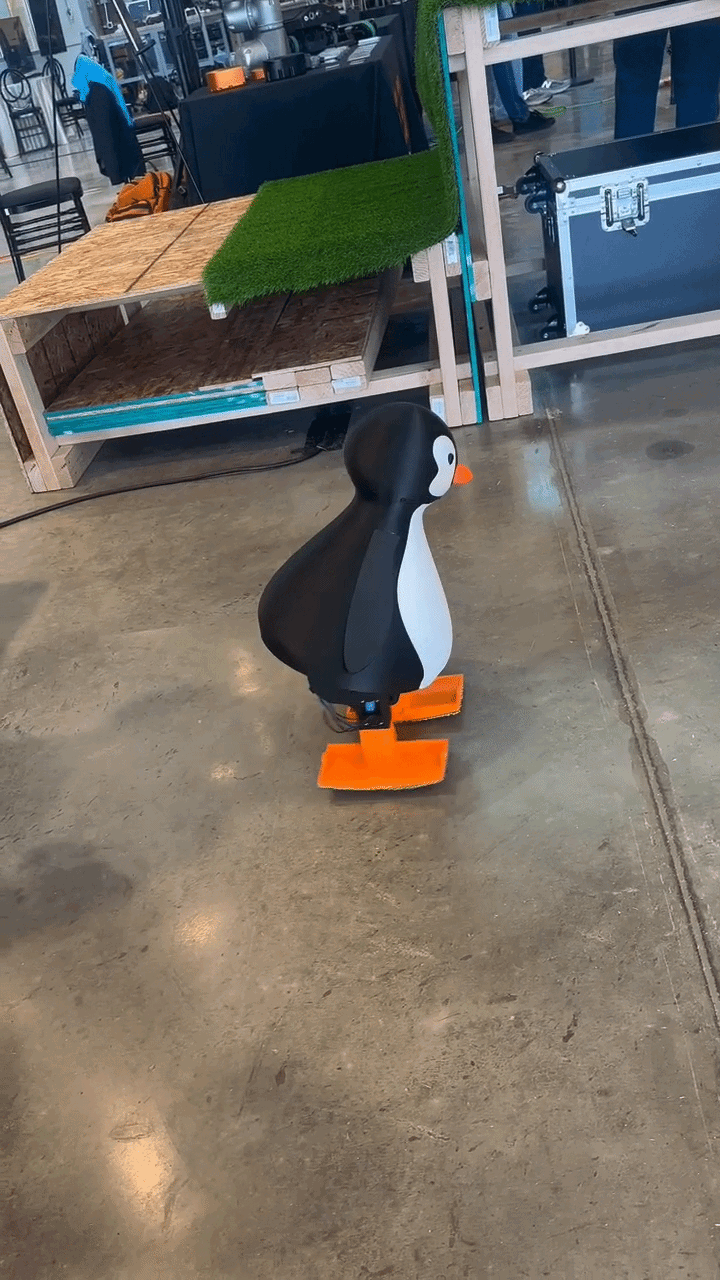
Pengu: Macaroni Penguin-inspired Bipedal Robot
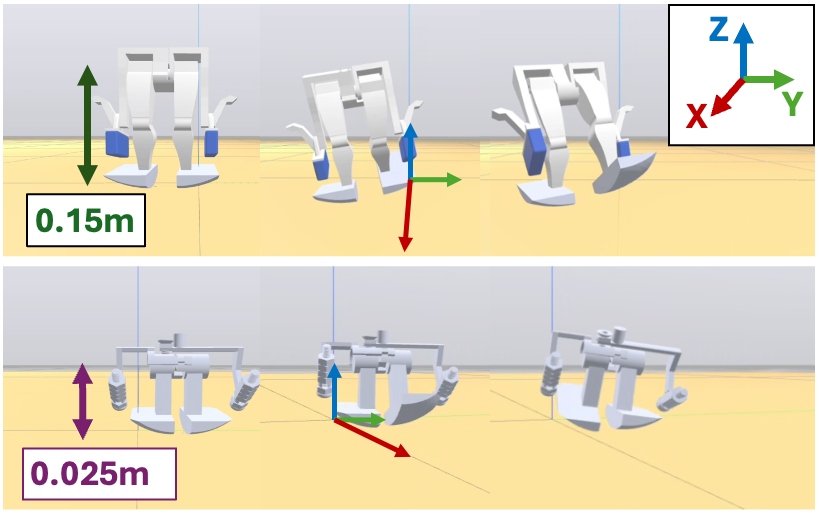
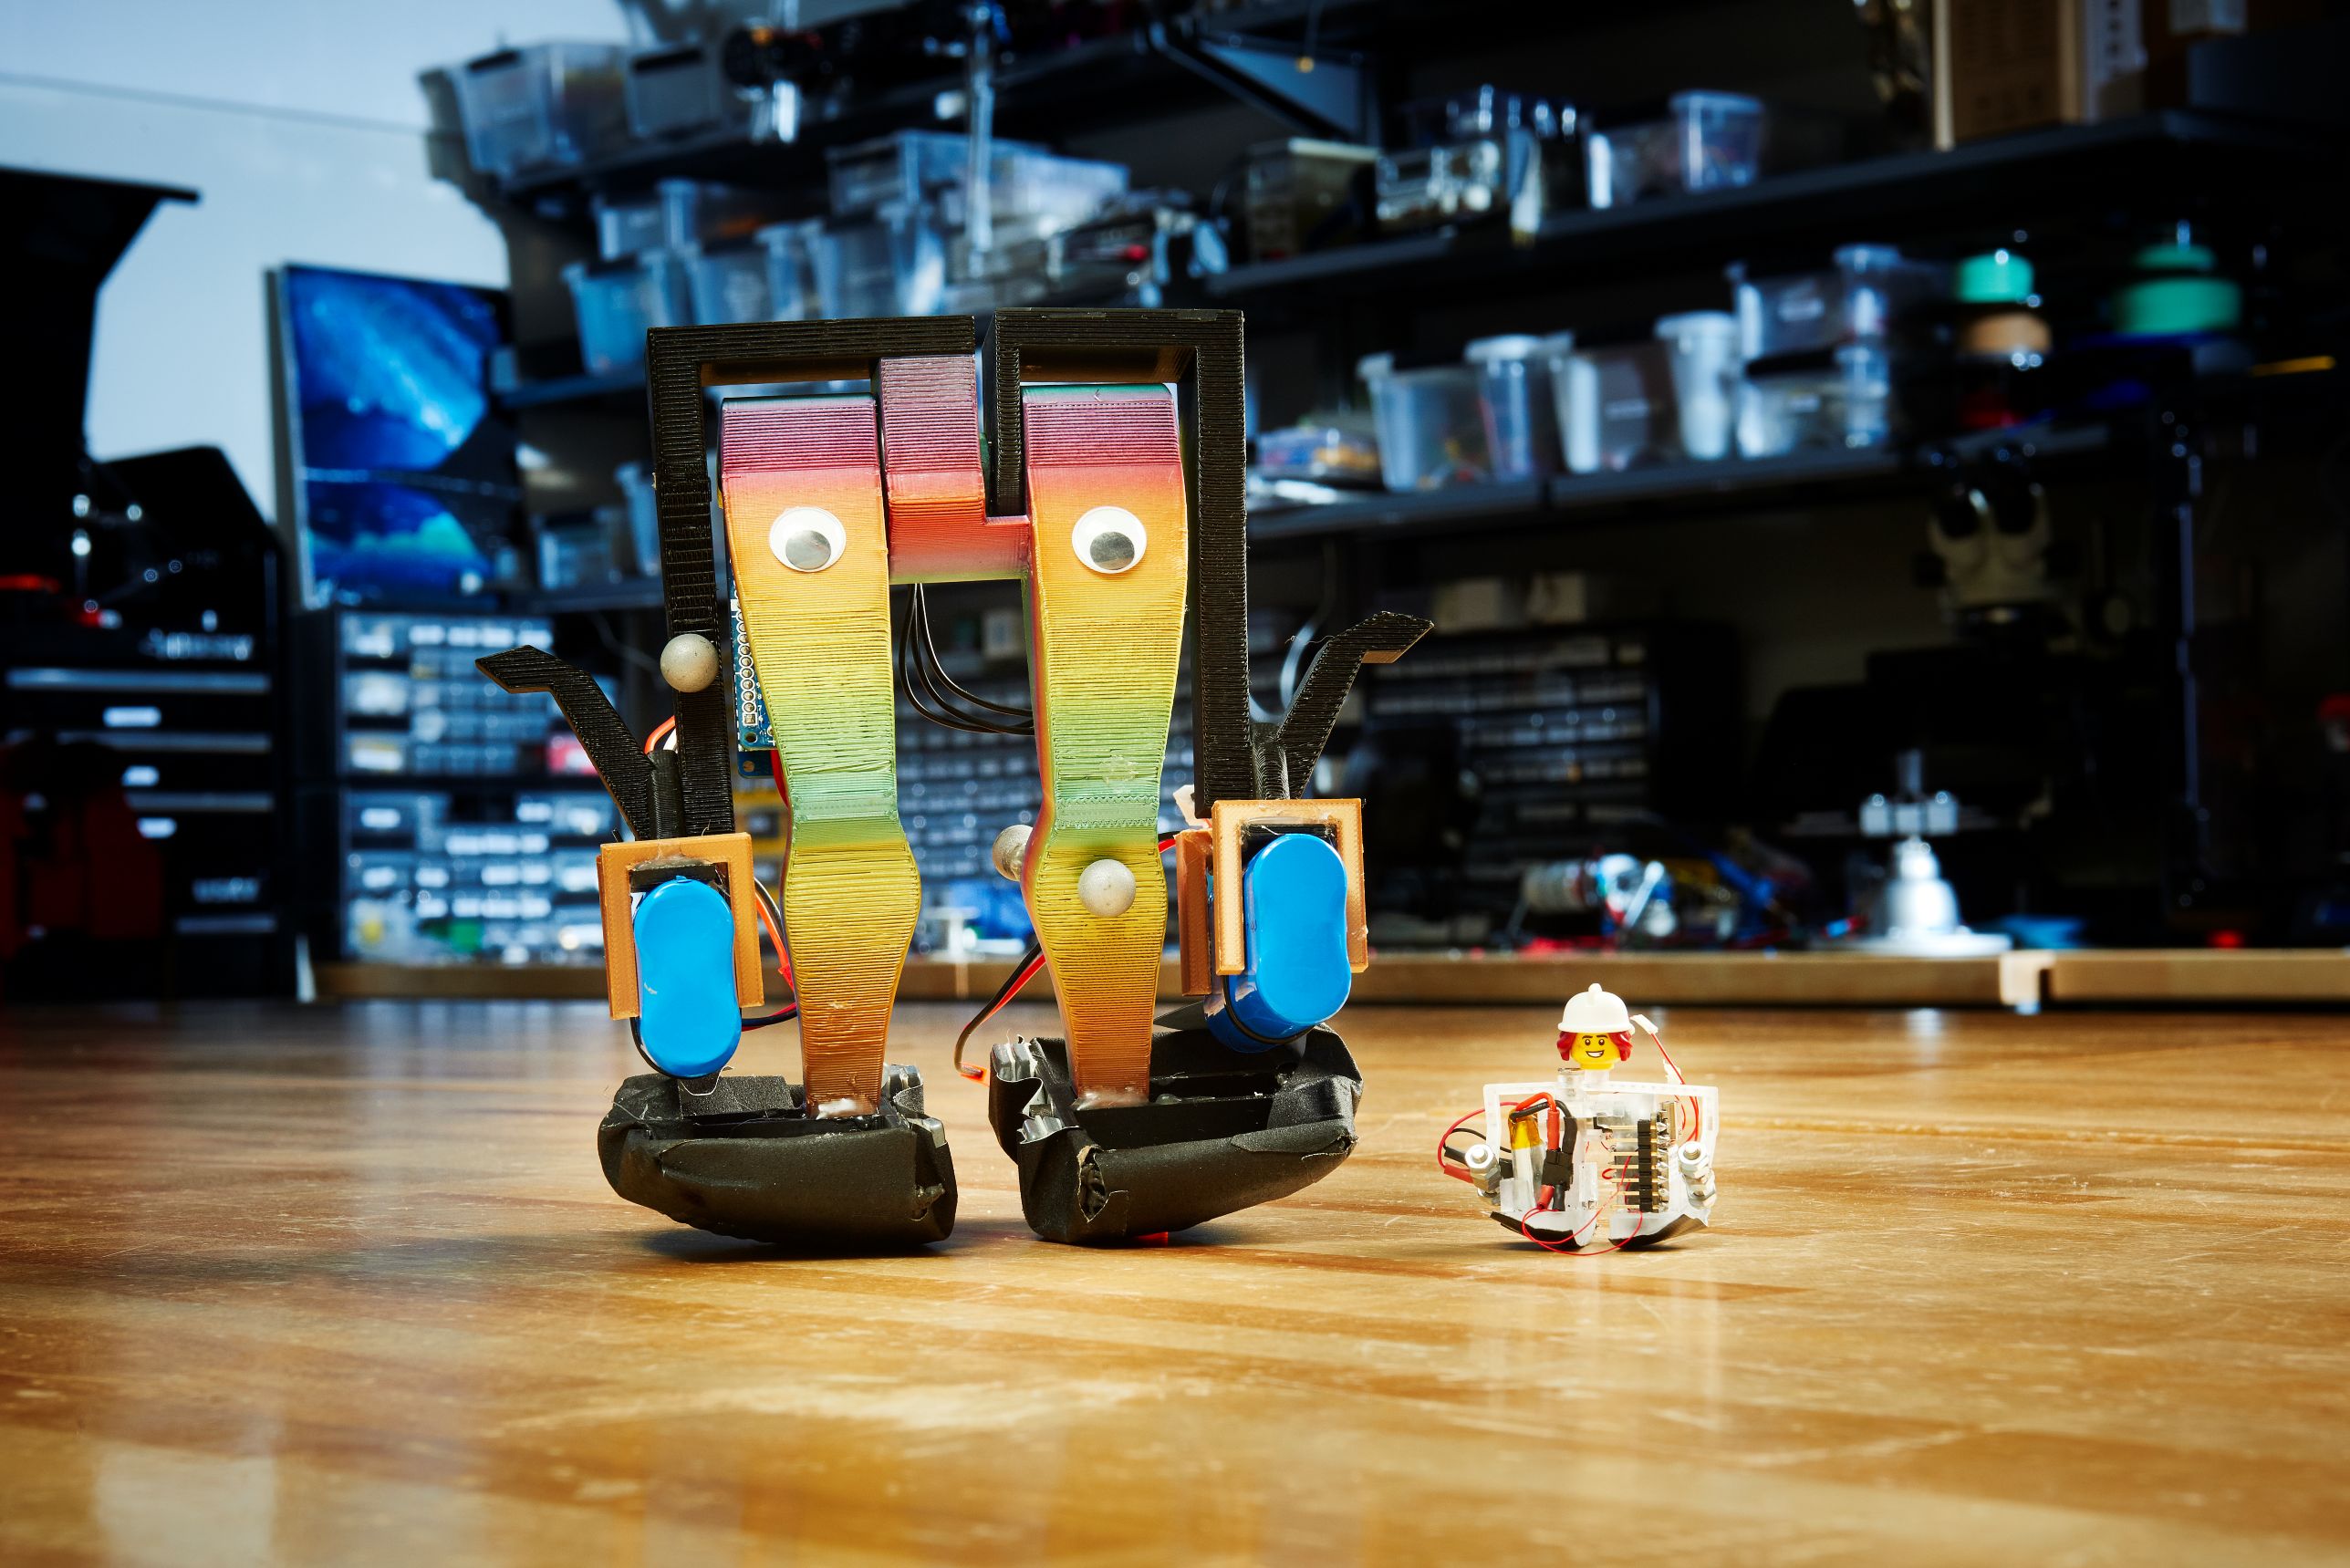
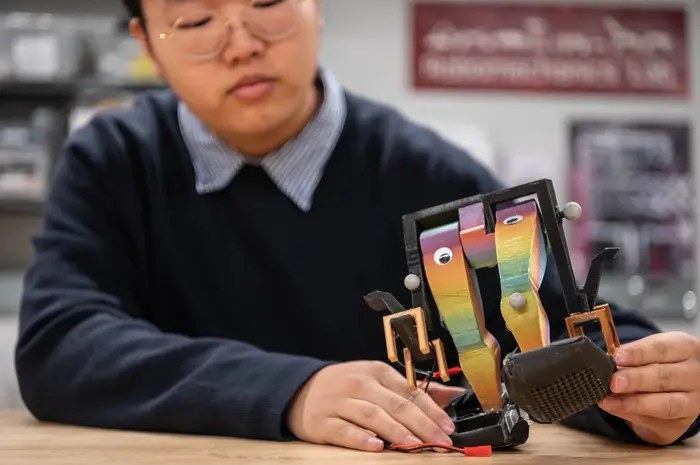
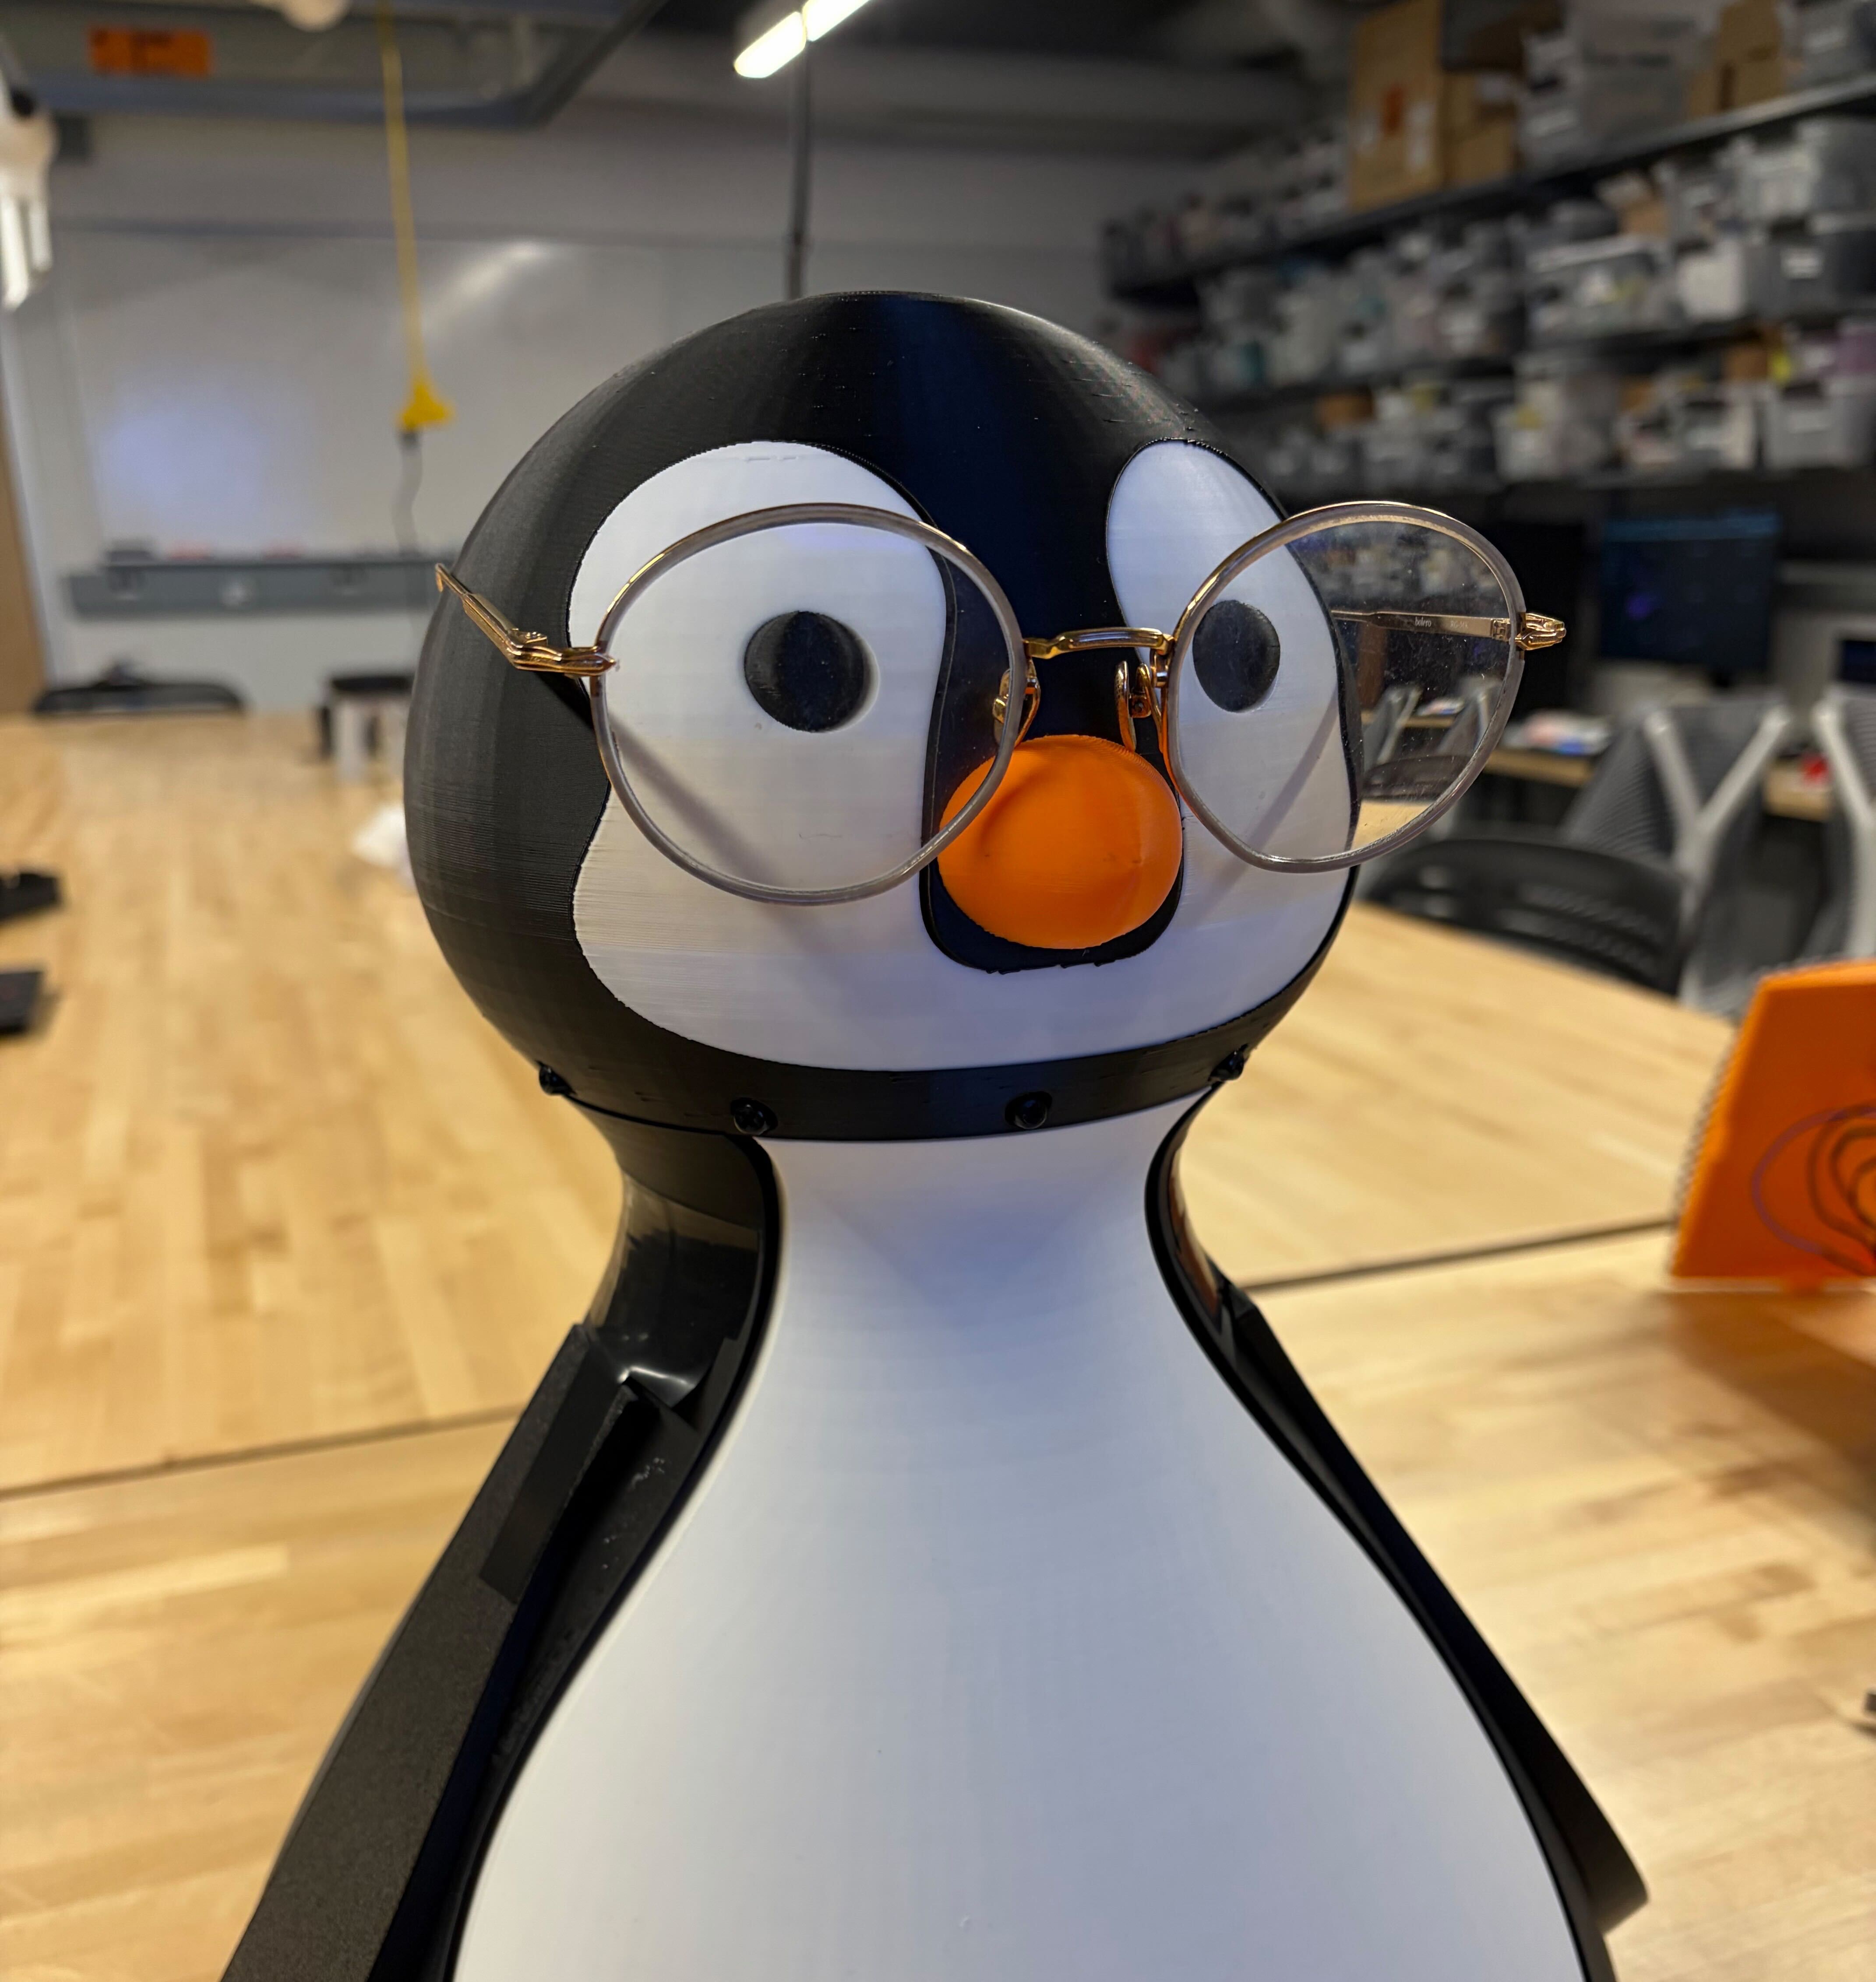
A 5-DOF biped with a crank-slider leg extension and adjustable center-of-mass height, built around macaroni penguin inertial properties. In MuJoCo and on hardware with motion capture, penguin-style torso-over-stance-leg motion with a high COM was 1.8× faster with 44% lower cost of transport than an upright gait at μ = 0.12, reversing at μ = 0.45. CPG-RL and imitation RL policies now climb 6° slopes at μ = 0.1 in simulation.
→ Co-first-author submission under review at ICRA 2027 · arXiv:2609.21185
→ Co-first-author workshop accepted at IROS 2026 (Pittsburgh, Oct)
→ Co-first-author workshop at ICRA 2026 (Vienna)
→ Featured at NFL Draft Tech Demo Day 2026
→ Live demo at Robotics & AI Discovery Day 2026 · featured by CMU College of Engineering
→ Live demo at NSF Foundational Research in Robotics (FRR), Pittsburgh 2026
→ Co-first-author workshop accepted at IROS 2026 (Pittsburgh, Oct)
→ Co-first-author workshop at ICRA 2026 (Vienna)
→ Featured at NFL Draft Tech Demo Day 2026
→ Live demo at Robotics & AI Discovery Day 2026 · featured by CMU College of Engineering
→ Live demo at NSF Foundational Research in Robotics (FRR), Pittsburgh 2026